|
|
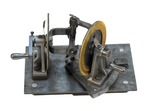
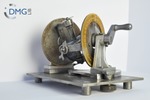
Universal Joint |
  | Click to enlarge |
|
Structure of mechanism |
| Function |
The model represents a universal joint, which is a pair of crossed axes meant to transform rotation around one axis to rotation around the second one. It is spatial mechanism. The model is used in the Mechanisms Laboratory of the University "Politehnica" of Timisoara. |
| Dimension of mechanism |
spherical |
| Number of links |
4 |
| Drive movement |
Rotation |
| Output movement |
Rotation |
| Degree of freedom |
1 |
| Fundamental mechanism |
 Link containing mechanism |
| Number of inputs |
1 |
| Number of followers |
1 |
| Revolution ability |
yes |
| Revolution ability of input link |
yes |
| Relative position between drive and output |
intersecting |
| |
Transfer function |
| Output motion |
revolving |
| Transfer function |
 identical direction  point symmetric |
| |
Application |
| Application area |
Various fields |
| |
|
| Collections |
| |
|
| Permanent links |
| |
|
| Data provider |
| |
|
| Administration |
| |
| Location |
|
University "Politehnica" Timisoara, Department of Mechatronics |
| Producer |
|
University "Politehnica" Timisoara, Department of Mechatronics |
| Date of production |
|
1980 |
| Construction, material |
|
Steel |
|
| Further media formats |
 Animations |
|
 CAX files |
|
 Videos |
|
 Images |
|


 Newsletter
 DMG-Lib

 Europeana

 UP Timisoara
 Start interactive animation


 Click to enlarge
