


 Newsletter
|
|
|||||||
Universal Joint |
|||||||
|---|---|---|---|---|---|---|---|
 Cliquez pour agrandir |
Description
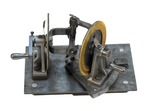
The model represents a universal joint, which is a pair of crossed axes meant to transform rotation around one axis to rotation around the second one. It is spatial mechanism. The model is used in the Mechanisms Laboratory of the University "Politehnica" of Timisoara. |
||||||
| Linked items | |||||||
|
|||||||
| Permanent links | |||||||
|
|||||||
| Data provider | |||||||
|
|||||||
| Administrative information | |||||||
|
|||||||
 DMG-Lib

 Europeana

 UP Timisoara
