 Premi per ingrandire |
Description
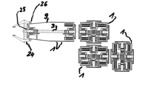
Several multi-block parts 1 form a multi-axis robotic arm with a terminator-24, which is designed as a gripping device. The gripping mechanism
of the end member 24 is here driven directly by a drive pinion 25 attached to the fixed, clip-compatible connecting flange to the rotation flange plug connection 2 of the multiblock standard part 1 is. In order for the adjustment of the gripping fingers
can be effected solely by the rotational movements of the rotation flange plug connection 2 via the drive pinion 25, the gripping mechanism is based here in bogie-5
26 from directing, which are attached to the multi-block housing 9. The multi-block parts 1 with gear used as the transmission gear 22 and 23, with a reconciliation of stocky rotational speeds of the inner and outer coils 8 ', 8 "inside the jo multiblock standard parts 1 are the end members 24 in particular used for applications where low peripheral speeds the end members 24 are required.
|


 Newsletter
 DMG-Lib

 Europeana

 RWTH Aachen
