


 Newsletter
|
|
|||||||
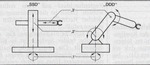
Comparison of the kinematic arrangement of SSD and DDD. S = shear joint, D = rotary joint. |
|||||||
|---|---|---|---|---|---|---|---|
 Premi per ingrandire |
Description
The figure describes a comparison of the loads acting on the actuators for different points of the working space. The SSD drives of the system are dependent with constant load torques (moments due to weight load of the cantilever and loaded negligible disturbing moments due to the coupling of the axes. |
||||||
| Linked items | |||||||
|
|||||||
| Permanent links | |||||||
|
|||||||
| Data provider | |||||||
|
|||||||
 DMG-Lib

 Europeana

 RWTH Aachen
