


 Newsletter
|
|
||||||||||
Lift system with kinematically dissimilar lift mechanisms |
||||||||||
|---|---|---|---|---|---|---|---|---|---|---|
 Click to enlarge |
Description
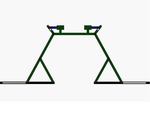
The motion device relates to a lift system with kinematically dissimilar lift mechanisms. The lift system is based on a linkage with 12 links and 16 joints, which is driven by two synchronised pistons. The degree of freedom of the mechanism is F = 1. |
|||||||||
| Technical data | ||||||||||
|
||||||||||
| Linked items | ||||||||||
|
||||||||||
| Permanent links | ||||||||||
|
||||||||||
| Data provider | ||||||||||
|
||||||||||
| Administrative information | ||||||||||
|
||||||||||

 DMG-Lib

 Europeana

 RWTH Aachen
