Structure of mechanism |
| Function |
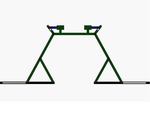
The motion device relates to a lift system with kinematically dissimilar lift mechanisms. The lift system is based on a linkage with 12 links and 16 joints, which is driven by two synchronised pistons. The degree of freedom of the mechanism is F = 1. |
| Dimension of mechanism |
planar |
| Number of links |
12 |
| Drive movement |
Rectilinear translation |
| Output movement |
Frame motion |
| Degree of freedom |
1 |
| Fundamental mechanism |
 Link containing mechanism |
| Number of inputs |
2 |
| Number of followers |
2 |
| Revolution ability |
no |
| Revolution ability of input link |
no |
| Relative position between drive and output |
orthogonal intersecting |
| |
Guidance function |
| Direction of the path |
reversed direction |
| Orientation of output link |
symmetrical |
| Trace of a dedicated point on follower |
 Open trace  Straight line motion |
| Dimension of mechanism |
planar |
| Input reference |
yes |
| Progress of orientation respecting output link |
oscillating: unknown range |
| |


 Newsletter
 Animations
 Videos
 Images

 DMG-Lib

 Europeana

 RWTH Aachen
 Click to enlarge
